Image Filtering
A filter makes a response map from an image: it brings out edges, blobs, textures, directions or frequencies. Radiomic features of the response map then describe these patterns. Pictologics has the filters of IBSI 2, and it checks them against the IBSI 2 reference maps. The IBSI 2 reference manual gives the definition and the formula of each filter.
Overview
A filtered configuration usually has these steps:
- Resample the image to cubic voxels, for example 1 × 1 × 1 mm. IBSI filters a resampled image.
- Resegment the ROI by intensity (for example a HU range), when you need it. Put this step before the filter: after a filter, a
resegmentstep reads the response values, not the HU values. - Filter the image.
- Discretise the response map, for texture, histogram and IVH features.
- Extract the features of the response map.
Every filter returns a float32 response map, half the memory of float64. Two rules set the type of the filter passes:
- Mean, Gaussian, Laws and wavelets: the passes run in float32 for every image. A float32 pass moves half the bytes, and the passes still sum each line in double (numba kernels with the arithmetic of scipy). The mean filter and the Laws energy sum each window on its own: the exact mean of the float32 values. So a value does not depend on where the image starts. For a float64 image, the response changes by the float32 rounding of the passes: about 1e-7 of the largest response.
- LoG, Simoncelli, Riesz and Gabor: a float64 image stays float64 in the passes and the FFTs, and the last step writes float32. A float64 image below 131,072 voxels (about 51³) runs its LoG passes in float32, as they are faster there. With a
padding_value, the padded image counts. The normalized convolution of a source mask also keeps a float64 image in float64.
Filter Reference
Pipeline type |
Function | IBSI code | Required parameters | Boundary default (pipeline / direct call) | With a source mask | IBSI 2 Phase 1 |
|---|---|---|---|---|---|---|
"mean" |
mean_filter |
S60F | none (support 15) |
mirror / zero | normalized convolution | 1.a.1 to 1.a.4 pass |
"gaussian" |
gaussian_filter |
8BC3 | sigma_mm |
mirror / zero | normalized convolution | no test |
"log" |
laplacian_of_gaussian |
L6PA | sigma_mm |
mirror / zero | normalized convolution | 2.a, 2.b pass |
"laws" |
laws_filter |
JTXT | none (kernel "L5E5E5") |
mirror / zero | normalized convolution (zero-fill when rotation invariant) | 3.a.1 to 3.b.3 pass |
"gabor" |
gabor_filter |
Q88H | sigma_mm, lambda_mm |
mirror / zero | zero-fill | 4.a.1 to 4.b.2 pass |
"wavelet" |
wavelet_transform |
none ("db2", level 1, "LHL") |
mirror / zero | zero-fill | 5.a to 7.a pass | |
"simoncelli" |
simoncelli_wavelet |
PRT7 | none (level 1) | periodic / periodic | zero-fill | 8.a.1 to 8.a.3 pass |
"riesz" |
riesz_transform, riesz_log, riesz_simoncelli |
AYRS | order ("base"), sigma_mm ("log") |
periodic / periodic | zero-fill | 9.a, 9.b.1, 10.b.1 pass |
- Direct calls: the functions are in
pictologics.filters. A direct call takesspacing_mm=1.0by default, sosigma_mmthen counts voxels. Give the spacing of your image. The pipeline gives it for Gaussian, LoG, Gabor and Riesz-LoG. - IBSI 2 Phase 1: 28 of 28 compared tests pass. 5 tests of 2D filters are not run: Pictologics filters 3D images (the Gabor filter works on 2D planes, as IBSI defines it). 3 tests have no reference map: 9.b.2 and 10.b.2 need structure-tensor steering, which Pictologics does not have, and the map of 10.a is missing. See the IBSI 2 Phase 1 report.
The Filter Figures
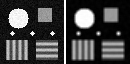
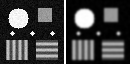
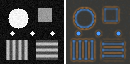
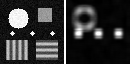
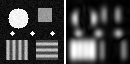
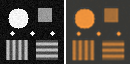
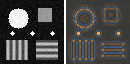
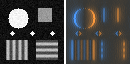
Each filter section below has a figure: the middle slice of a 3D test image of 64 × 64 × 64 voxels of 1 mm (left), and the response of the filter (right). Move the slider, or press Play, to see the response at other settings.

The test image has:
- a large sphere (a blob) and three small spheres (small blobs);
- a cube (edges and corners);
- two striped patches with a period of 6 mm: the left patch changes along x, the right patch along y;
- noise.
The colours of the responses:
- Grey (mean, Gaussian, Laws energy, Gabor): dark is low, and bright is high.
- Blue and orange (LoG, wavelets, Simoncelli, Riesz): blue is below 0, dark grey is 0, and orange is above 0.
Each response has its own scale. The spatial filters use the mirror boundary, and the Simoncelli and Riesz filters the periodic boundary (the defaults of a pipeline step). The script dev/docs_figures.py makes the figures with the Pictologics filters.
Boundaries and Padding
A filter reads voxels past the image edge. The boundary sets their values:
boundary |
The voxels past the edge |
|---|---|
"mirror" |
The image, mirrored at its edge (IBSI recommends it for most tests) |
"nearest" |
The value of the nearest edge voxel |
"periodic" |
The image from its other side (the FFT filters work so) |
"zero" (or "constant") |
A constant: 0, or padding_value |
- Defaults: a pipeline filter step uses
"mirror", except the Simoncelli and Riesz filters, which use"periodic". A direct call uses"zero"(spatial filters) or"periodic"(FFT filters). Giveboundaryin every step to make it clear. -
Constant value padding (IBSI 2 Z3VE): with
"constant",padding_valuesets the constant, for example -1000 to pad a CT image with air:{"step": "filter", "params": { "type": "log", "sigma_mm": 2.0, "boundary": "constant", "padding_value": -1000.0, }}Every filter takes
padding_value. A value other than 0 needs the"constant"(or"zero") boundary; with another boundary, the filter raisesValueError. A spatial filter gives the response of the image padded with the constant as far as the filter reads (no padded copy is made). A Laws energy step then pads the response with 0.
FFT Filter Boundaries
The Simoncelli and Riesz filters work in the Fourier domain, which is periodic:
"periodic"(default): the FFT works on the image as it is. This is the fastest path, and the one that IBSI specifies for the Simoncelli tests."zero","nearest","mirror": the filter pads the image with the requested mode, filters, and cuts the result back. A composite filter (riesz_log,riesz_simoncelli) pads once around the whole chain.riesz_logthen does the LoG and the Riesz transform in one FFT round trip on the padded image.
Requested and effective boundary
The transform stays periodic on the padded image, so a non-periodic boundary is honoured only approximately: the Riesz kernel has long tails, and no finite pad removes all of its error. The capability metadata calls this as_specified_via_padding (see FILTER_CAPABILITIES), and the log entry of each filter step records the requested and the effective boundary. The boundary that a test specifies gives better agreement with its IBSI reference map: for IBSI 2 Phase 1 test 10.b.1, "nearest" makes the largest error about four times smaller.
Cost of a non-periodic boundary
The pad makes the array larger. On a 64³ image, Simoncelli at level 1 then works on 2.0 times the voxels and takes 1.5 times as long; Riesz 3.4 and 3.0 times; Riesz-Simoncelli at level 1 5.4 and 3.1 times; Riesz-LoG at σ 2 mm 5.4 and 1.0 times. The pad grows with the scale of the filter. Use a non-periodic boundary only when you need it.
Filters in a Pipeline
- Checks:
add_configchecks every filter step. An unknown parameter gets a hint ("kernels"gives "did you mean 'kernel'?"). A missingsigma_mm,lambda_mmororderis an error, and so is a bad wavelet level or decomposition, a bad Riesz order, an unknown Gaborresponse, or apadding_valuewithout the constant boundary. - FBS after a filter: the response has other units than the image, so a filter step cancels the FBS start of an earlier
resegmentstep. An FBSdiscretisestep after a filter needsmin_val, or aresegmentstep after the filter (IBSI asks for a fixed start). - The region around the ROI: often no later step reads the image away from the ROI. Then the mean, Gaussian, LoG, Laws, wavelet and Gabor filters compute only the region around the ROI box. The region grows by the reach of the filter. The pipeline then keeps only that region: the image and the masks are cut to it, as after a discretise step. The features are the same, bit for bit, and a small ROI in a large image costs much less time. A later filter, resample,
binarize_maskthat keeps the value 0, or whole-imagenormalisestep needs the whole grid. See Tips for Speed and Memory. - The log: the log entry of each filter step records
boundary_requested,boundary_effective,params_requestedandparams_effective(with the spacing and the boundary that the pipeline gave).
Mean Filter
The mean filter replaces each voxel with the mean of the cube of support voxels around it. It smooths the image and reduces noise.
| Parameter | Type | Default | Description |
|---|---|---|---|
support |
int |
15 |
The edge of the cube in voxels (odd), for example 3 for 3 × 3 × 3 |
Gaussian Filter
The Gaussian filter smooths the image with a Gaussian kernel of scale σ (in mm). It keeps the coarse structure and removes fine detail and noise.
| Parameter | Type | Default | Description |
|---|---|---|---|
sigma_mm |
float |
required | The scale of the Gaussian (mm) |
truncate |
float |
4.0 |
The kernel ends at this many σ |
spacing_mm |
float or tuple |
1.0 |
The voxel spacing (the pipeline gives it) |
Laplacian of Gaussian (LoG)
The LoG filter smooths the image with a Gaussian of scale σ, and then takes the Laplacian (the second derivative). It brings out edges and blobs of a size near σ: a larger σ finds larger blobs.
| Parameter | Type | Default | Description |
|---|---|---|---|
sigma_mm |
float |
required | The scale of the Gaussian (mm) |
truncate |
float |
4.0 |
The kernel ends at this many σ (IBSI) |
spacing_mm |
float or tuple |
1.0 |
The voxel spacing (the pipeline gives it) |
Many scales
Add one configuration for each σ (for example 1, 2, 3, 4 and 5 mm). Configurations with the same first steps share them, so the resample runs once.
Laws Texture Energy
Laws filters combine three 1D kernels (L: level, E: edge, S: spot, W: wave, R: ripple) into one 3D kernel, for example "L5E5S5". Each kernel brings out one type of texture.
| Parameter | Type | Default | Description |
|---|---|---|---|
kernel (pipeline), kernels (direct call) |
str |
"L5E5E5" in the pipeline |
The 3D kernel. pictologics.filters.LAWS_KERNELS lists the 1D kernels |
rotation_invariant |
bool |
False |
Pool the response over the 24 right-angle rotations of the kernel |
pooling |
str |
"max" |
How to pool the rotations: "max", "min" or "average" |
compute_energy |
bool |
False |
Give the texture energy: the mean of the absolute response in a cube of 2 × energy_distance + 1 voxels |
energy_distance |
int |
7 |
The half-width of the energy cube (Chebyshev distance) |
Gabor Filter
A Gabor filter is a complex sine wave in a Gaussian envelope. It brings out texture of one wavelength and one direction. Pictologics applies 2D Gabor kernels in the axial plane, or in all three orthogonal planes, as IBSI defines them.
| Parameter | Type | Default | Description |
|---|---|---|---|
sigma_mm |
float |
required | The width of the Gaussian envelope (mm) |
lambda_mm |
float |
required | The wavelength of the sine wave (mm) |
gamma |
float |
1.0 |
The aspect ratio of the envelope. The kernel radius is ceil(6σ / min(1, γ)) |
theta |
float |
0.0 |
The direction of the filter, in radians |
rotation_invariant |
bool |
False |
Pool the response over the directions 0, delta_theta, 2 × delta_theta, ... |
delta_theta |
float |
required with rotation_invariant |
The step between the directions, in radians. A step near 2π / n (within 1e-3) gives exactly n directions, so a rounded π/4 works |
pooling |
str |
"average" |
How to pool the directions: "average", "max" or "min" |
average_over_planes |
bool |
False |
Average the response over the three orthogonal planes (else the axial plane only) |
response |
str |
"modulus" |
The part of the complex response (IBSI 2 5P3T): "modulus", "angle" (radians), "real" or "imaginary". Pooling pools this part |
spacing_mm |
float or tuple |
1.0 |
The voxel spacing (the pipeline gives it). Each plane scales its kernel by its own in-plane spacing |
Separable Wavelets
A separable wavelet transform splits each axis into a low (L) and a high (H) frequency part. A 3D image so gives 8 sub-bands (LLL, LLH, ..., HHH). Pictologics uses the undecimated (stationary) transform, so the response map has the size of the image.
| Parameter | Type | Default | Description |
|---|---|---|---|
wavelet |
str |
"db2" |
The wavelet: "haar", "dbN" (for example "db3"), "coifN" (for example "coif1"), and the other PyWavelets names |
level |
int |
1 |
The decomposition level: a whole number of 1 or more |
decomposition |
str |
"LHL" |
The sub-band: three letters of L or H (lower case works) |
rotation_invariant |
bool |
False |
Pool the response over the 24 right-angle rotations of the image |
pooling |
str |
"average" |
How to pool the rotations: "average", "max" or "min" |
Simoncelli Wavelet
The Simoncelli wavelet is a non-separable, isotropic wavelet: it has no preferred direction. Use it when the direction of a texture does not matter.
| Parameter | Type | Default | Description |
|---|---|---|---|
level |
int |
1 |
The decomposition level: a whole number of 1 or more |
IBSI 2 Phase 3
The IBSI 2 Phase 3 manual names the mirror boundary for its Simoncelli filter, but the Phase 3 checks of Pictologics use the periodic default, as the Phase 1 tests do. See the Phase 3 report.
Riesz Transform
The Riesz transform is a higher-order derivative in all directions at once. Its order (l1, l2, l3) gives the derivative order along each axis. Pictologics combines it with a LoG or a Simoncelli filter. It does not steer the filters (no structure-tensor alignment).
| Parameter | Type | Default | Description |
|---|---|---|---|
variant |
str |
"base" |
Pipeline only: "base" calls riesz_transform, "log" calls riesz_log, "simoncelli" calls riesz_simoncelli |
order |
tuple |
required for "base"; (1, 0, 0) otherwise |
One whole number of 0 or more for each axis, with a sum above 0 |
sigma_mm, spacing_mm, truncate |
sigma_mm required for "log" |
The LoG of the "log" variant (the pipeline gives the spacing) |
|
level |
int |
1 |
The Simoncelli level of the "simoncelli" variant |
With the periodic boundary, the LoG stage of riesz_log uses the zero boundary. With another boundary, the whole chain uses the requested boundary.
Source Masks for Sentinel Values
Some images hold a sentinel value where they have no data, for example -2048 HU outside the field of view. These values would spoil a filter response. Every filter takes a source_mask (True: a voxel with data):
| Filters | Method |
|---|---|
| Mean, Gaussian, LoG, Laws | Normalized convolution: each response voxel is the weighted mean of the valid voxels only |
| Laws (rotation invariant), Gabor, wavelets, Simoncelli, Riesz | Zero-fill: the invalid voxels become 0 before the filter |
In a Pipeline
The pipeline makes the source mask from the source_mode of the configuration, and gives it to the filter. In "auto" mode with sentinel_value, the valid voxels are those without the sentinel value; in "roi_only" mode, the voxels of the ROI.
pipeline.add_config(
    "filtered_features",
    [
        {"step": "resample", "params": {"new_spacing": (1.0, 1.0, 1.0)}},
        {"step": "resegment", "params": {"range_min": -1000, "range_max": 3000}},  # HU, before the filter
        {"step": "filter", "params": {"type": "log", "sigma_mm": 3.0, "boundary": "mirror"}},
        {"step": "discretise", "params": {"method": "FBN", "n_bins": 32}},
        {"step": "extract_features", "params": {"families": ["intensity", "texture"]}},
    ],
    source_mode="auto",
    sentinel_value=-2048,
)
A resample step also removes the voxels without data from the masks. Without a resample step, a resegment step before the filter keeps the sentinel voxels out of the intensity mask (the voxels of the intensity and texture features).
In a Direct Call
from pictologics.filters import gabor_filter, laplacian_of_gaussian, mean_filter

valid = image_array > -2000  # True: a voxel with data

# Mean, Gaussian, LoG and Laws return (response, valid mask) with a source mask
response, response_valid = mean_filter(image_array, support=15, source_mask=valid)
response, response_valid = laplacian_of_gaussian(image_array, sigma_mm=3.0, source_mask=valid)

# The other filters return the response only
response = gabor_filter(image_array, sigma_mm=5.0, lambda_mm=2.0, source_mask=valid)
See also: Source Modes and Sentinel Values, the filter API and the IBSI 2 reports.